Xinyuan Zhang

I am a final-year undergraduate in Artificial Intelligence at the University of Chinese Academy of Sciences. I was a visiting student in the Department of Computer Science at the University of Oxford.
During my time at Oxford, I worked as a research assistant with the Dynamic Robot Systems Group (DRS) at the Oxford Robotics Institute (ORI), focusing on 3D building layout reconstruction from monocular image sequences, where I was fortunate to be supervised by Prof. Maurice Fallon and Prof. Yifu Tao. Previously, I worked at the Institute of Automation, Chinese Academy of Sciences on vision-language navigation for autonomous delivery scenarios, where I was advised by Prof. Fei-Yue Wang and Prof. Yonglin Tian.
I am interested in 3D vision and robotic perception. My goal is to develop models and systems that truly understand the physical world and leverage them for real-world robotics.
Education
| University of Chinese Academy of Sciences (UCAS), Beijing, China Bachelor of Engineering in Artificial Intelligence | 2023.09 – 2027.06 |
| University of Oxford, Oxford, UK Visiting Student in Computer Science (Major), Mathematics (Minor) | 2025.10 – 2026.07 |
Experience
| Research Assistant Dynamic Robot Systems Group, Oxford Robotics Institute (ORI), Oxford, UK 3D building layout reconstruction from monocular image sequences. Supervisor: Prof. Maurice Fallon and Prof. Yifu Tao | 2026.01 – 2026.09 |
| Research Intern Institute of Automation, Chinese Academy of Sciences (CASIA), Beijing, China Vision-Language Navigation (VLN) in Intelligent Logistics. Supervisor: Prof. Fei-Yue Wang and Prof. Yonglin Tian | 2024.02 – 2025.10 |
Honors and Awards
| National Scholarship Ministry of Education, China | 2024, 2025 |
| First-Class Undergraduate Academic Scholarship (Top 5% in UCAS) University of Chinese Academy of Sciences (UCAS) | 2024, 2025 |
Selected Publications
- Under Review
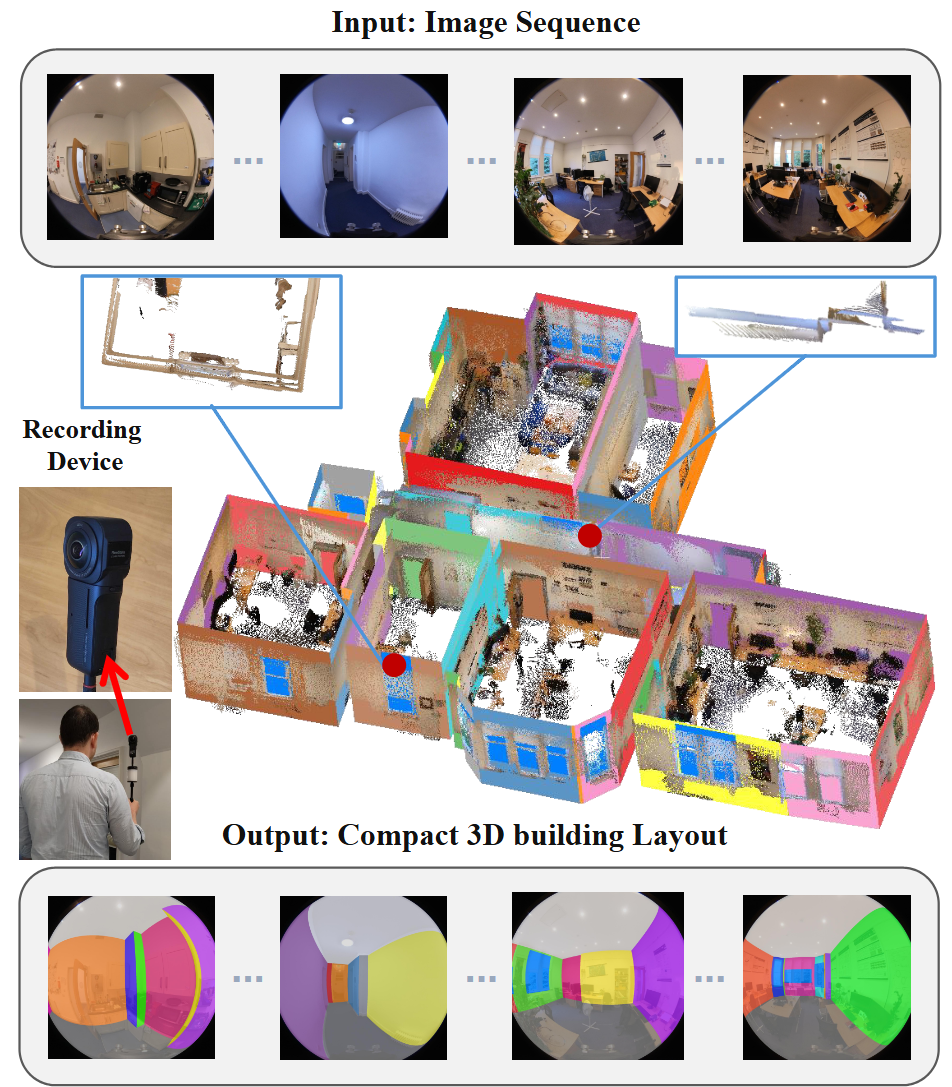 SeqLayout3D: Room-wise 3D Building Layout Reconstruction from Monocular Image SequencesUnder Review , 2026
- ITSC
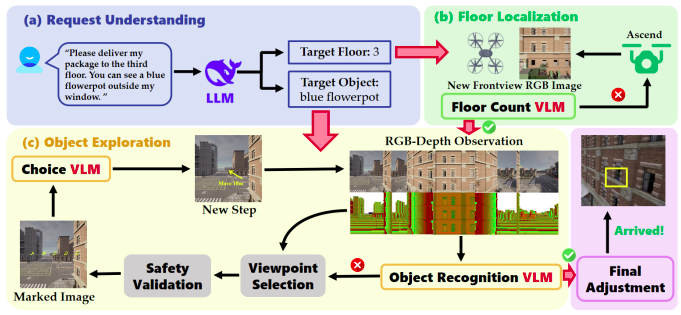 LogisticsVLN: Vision-Language Navigation For Low-Altitude Terminal Delivery Based on Agentic UAVsIn 2025 IEEE 28th International Conference on Intelligent Transportation Systems (ITSC), 2025
- SOLI
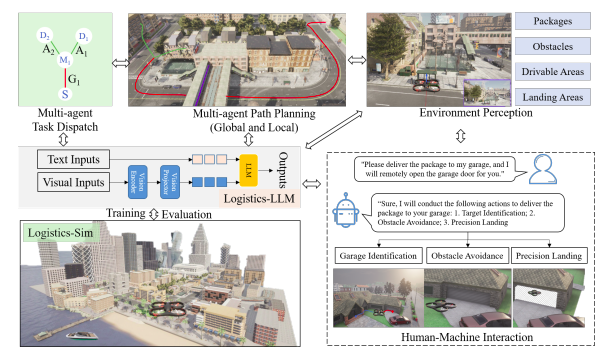 LogisticsVISTA: 3D Terminal Delivery Services With UAVs, UGVs and USVs Based on Foundation Models and Scenarios EngineeringIn 2024 IEEE International Conference on Service Operations and Logistics, and Informatics (SOLI), 2024